EMBODIED INTELLIGENCE

Siyuan Liu

Fourth-year Ph.D. student

Institute of Automation,
Chinese Academy of Sciences (CASIA)

Chinese Academy of Sciences logoCASIA logo

I study how robots learn to move and manipulate through vision-language-action (VLA) models, reinforcement learning, and musculoskeletal systems.

My previous research focused on manipulation in musculoskeletal systems. I am now exploring how large-scale models can enable manipulation and coordinated loco-manipulation.

Siyuan Liu standing beside a river

News

Our paper MyoChallenge 2025 was accepted to NeurIPS 2026, Datasets and Benchmarks Track.

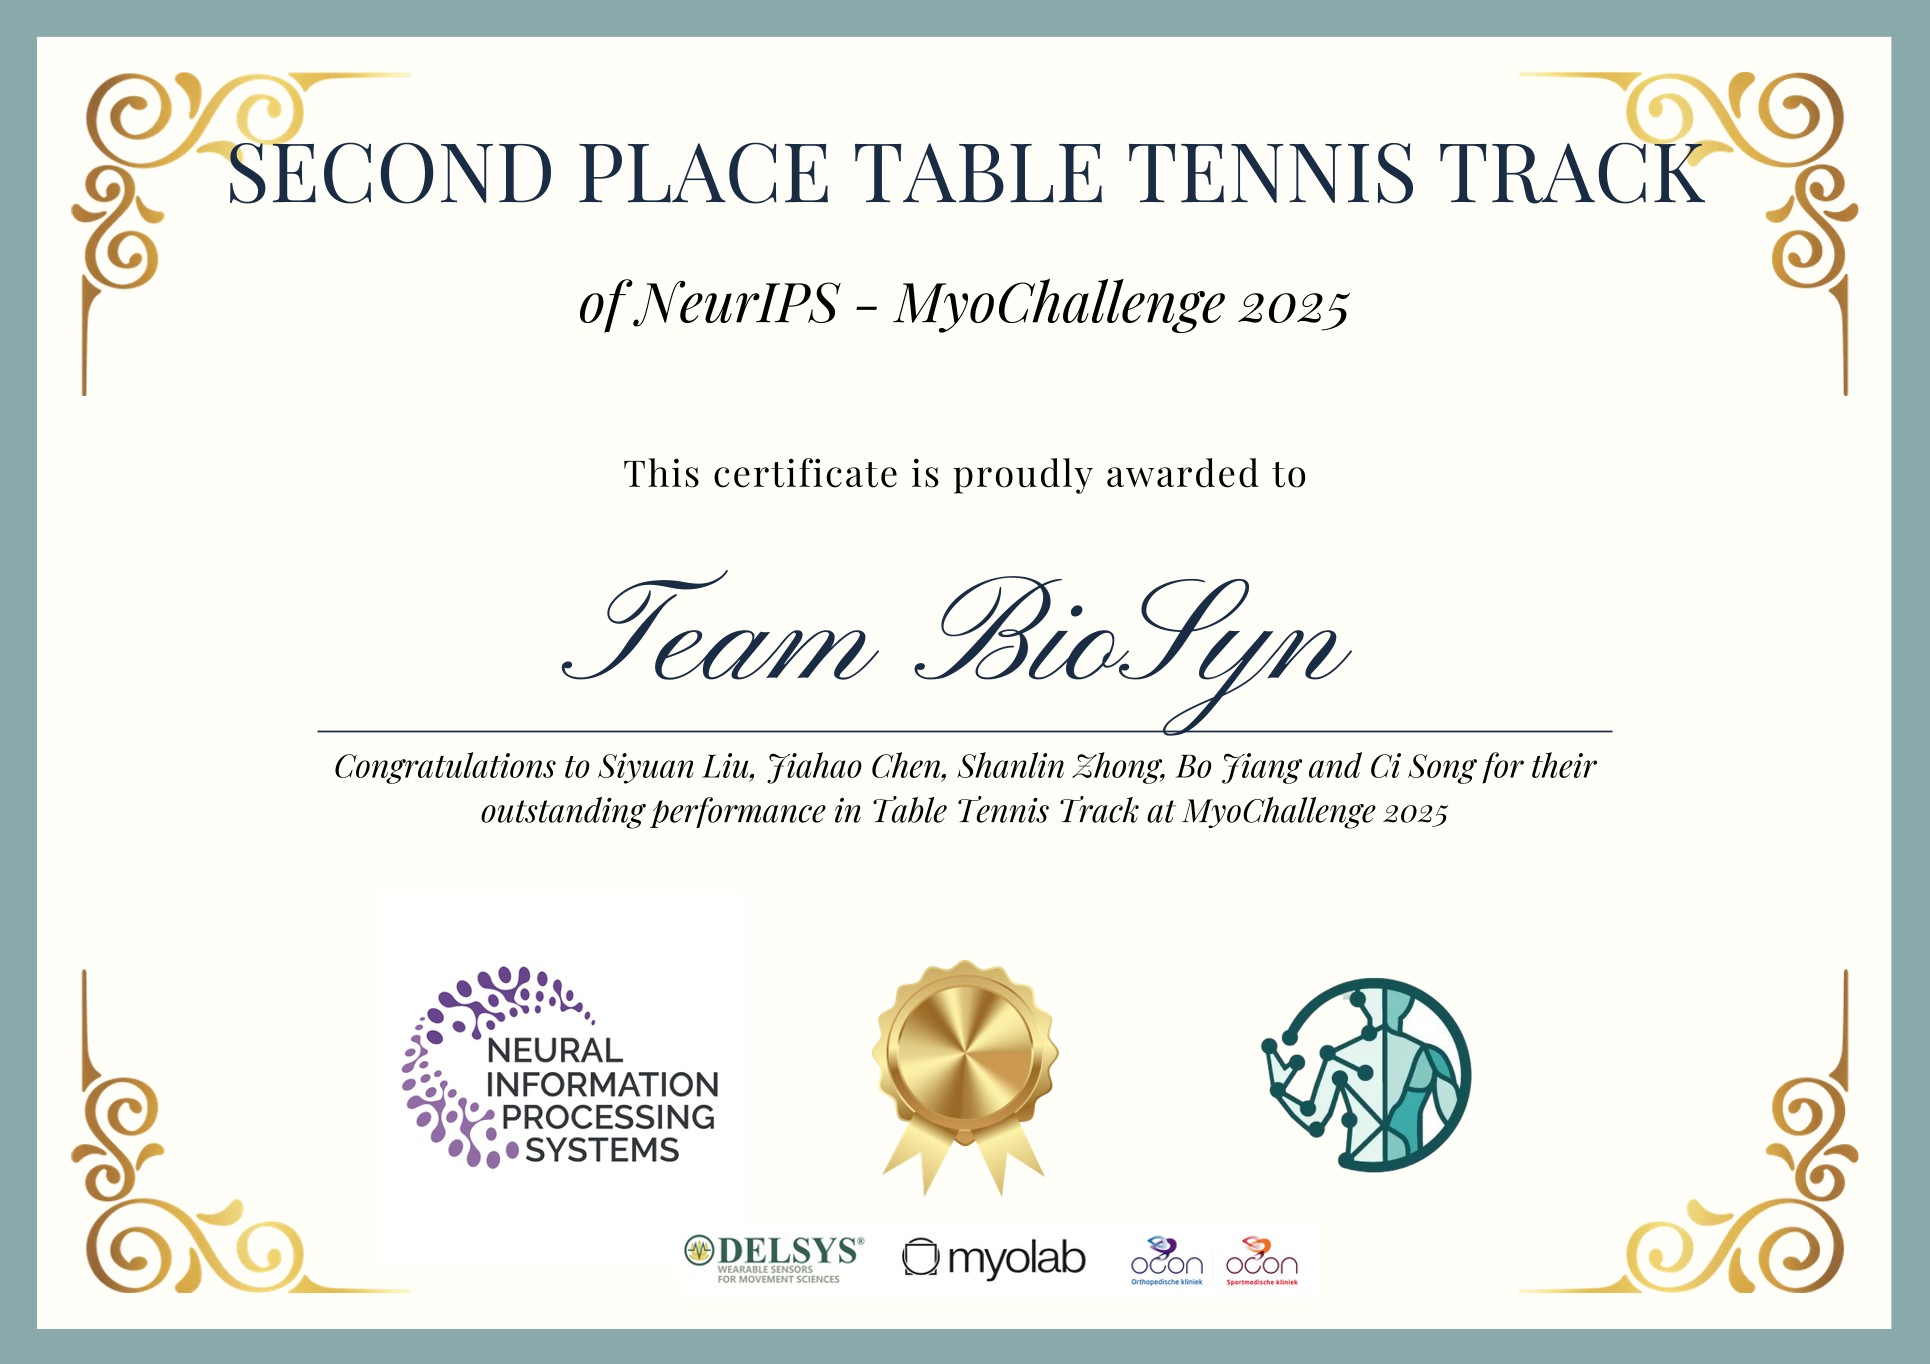
Runner-up in the Table Tennis Track at the NeurIPS MyoChallenge 2025.

Publications

Download BibTeX
TASE2026
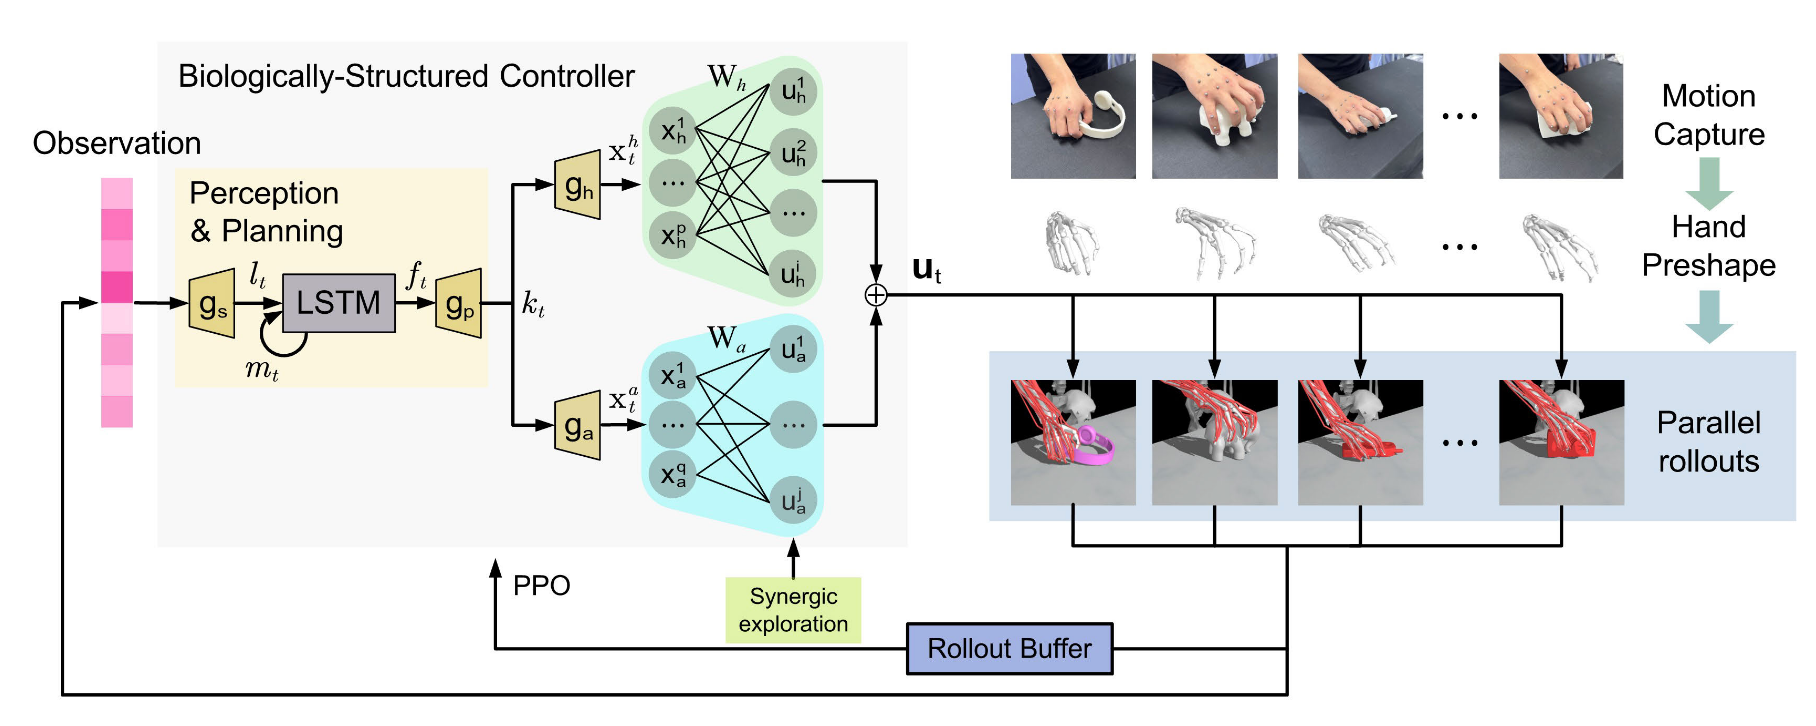
BioSynGrasp framework with a biologically structured controller, synergic exploration, and human demonstrations

BioSynGrasp: Bio-Inspired Structured Reinforcement Learning With Synergetic Exploration and Human Demonstration for Dexterous Grasping of Musculoskeletal Robot

Siyuan Liu, Bo Jiang, Lijun Han, Shanlin Zhong, Ci Song, Huaping Liu, Jiahao Chen

IEEE Transactions on Automation Science and Engineering · 2026

TCDS2026
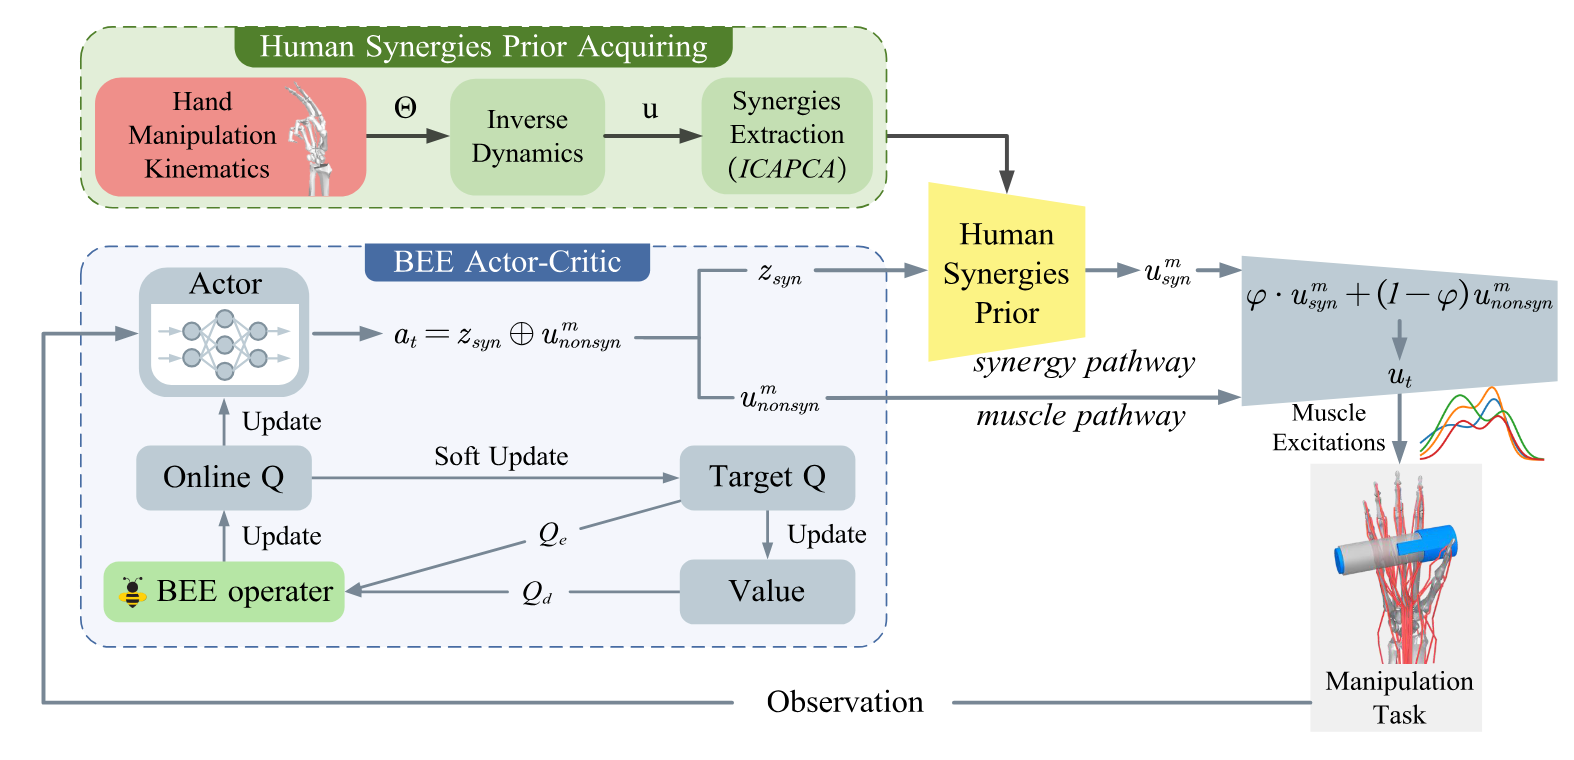
Human synergies prior acquisition and BEE actor-critic framework for musculoskeletal manipulation

Enhancing Musculoskeletal Manipulation Skills through Human Synergies Prior and BEE Actor-Critic

Siyuan Liu, Jiahao Chen, Bo Jiang, Ci Song, Shanlin Zhong

IEEE Transactions on Cognitive and Developmental Systems · 2026

IJCNN2026
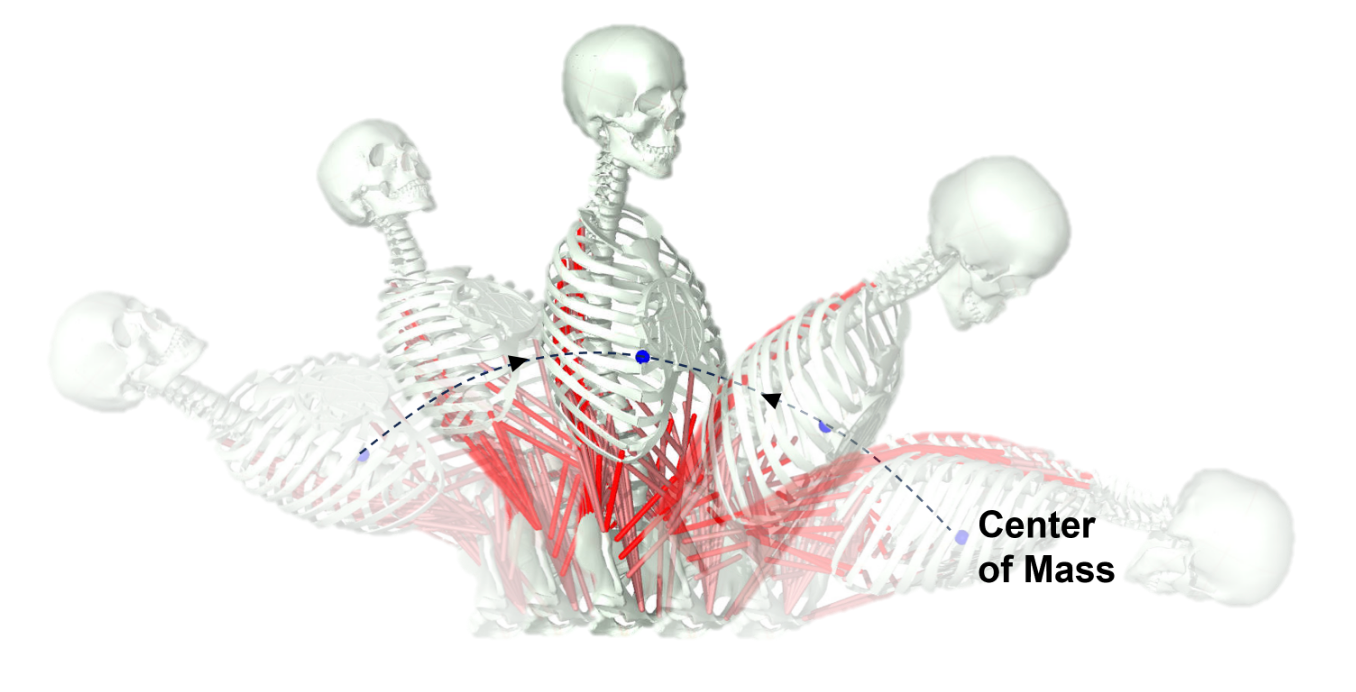
Musculoskeletal torso balance model showing motion and the center-of-mass trajectory

Probing the Functional Role of Muscle Synergies in Reinforcement Learning–Based Torso Balance via Neural Reconstruction and Synergy Ablation

Siyuan Liu, Jiahao Chen

2026 International Joint Conference on Neural Networks · 2026

EMBC2026
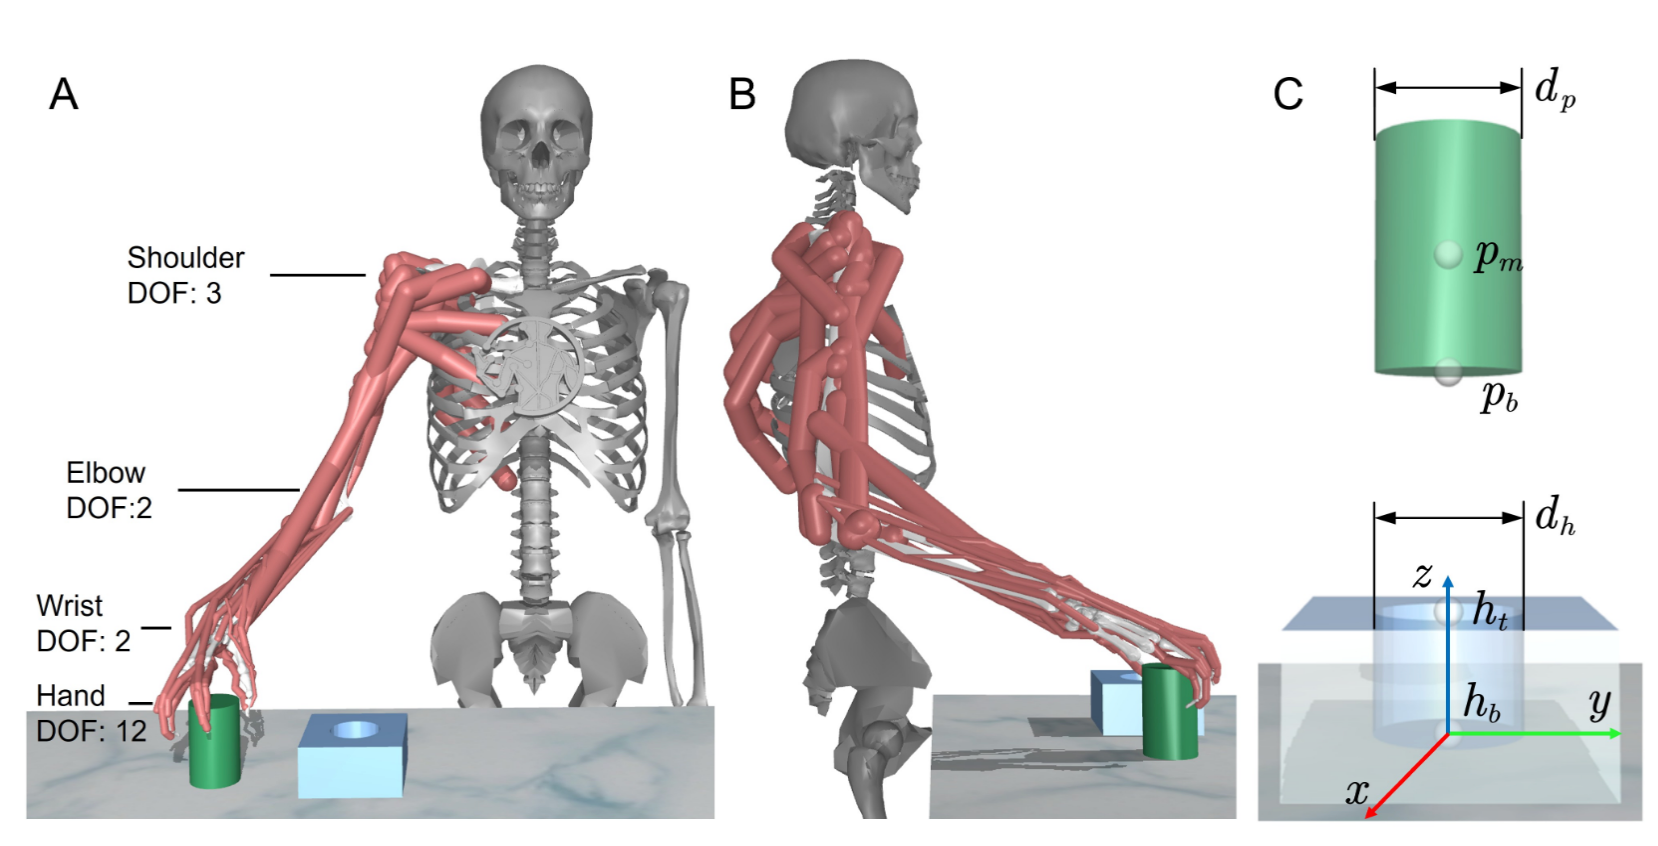
Musculoskeletal upper-body model and peg-in-hole assembly task geometry

Robust Peg-in-Hole Assembly for a Musculoskeletal System via Environment-Constrained Curriculum Learning

Siyuan Liu, Jiahao Chen

48th Annual International Conference of the IEEE Engineering in Medicine and Biology Society · 2026

YAC2025
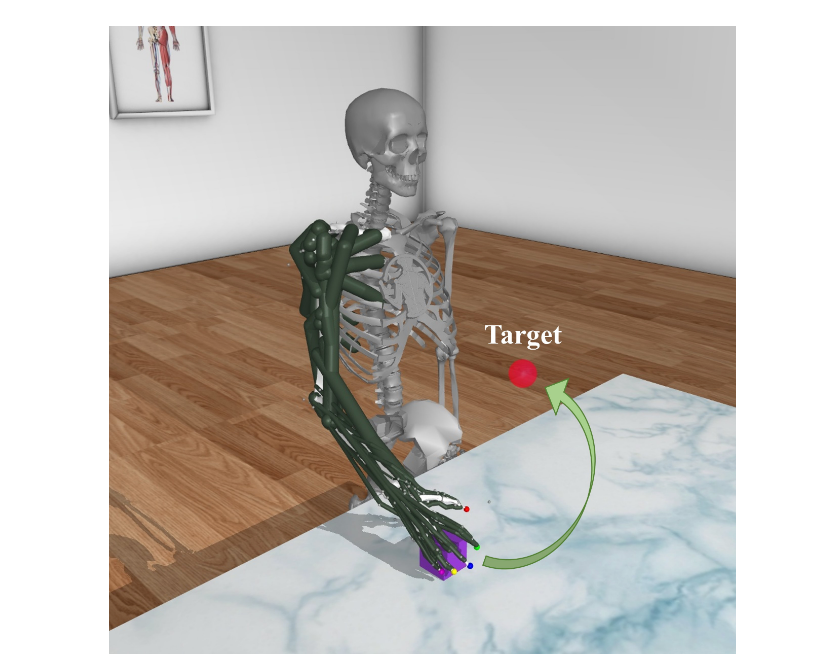
Musculoskeletal robot grasping and moving an object toward a target

Proximal Policy Optimization with Reward Shaping for Musculoskeletal Robot Grasping

Siyuan Liu, Ci Song, Bo Jiang, Jiahao Chen

2025 40th Youth Academic Annual Conference of Chinese Association of Automation · 2025

ICARM2026
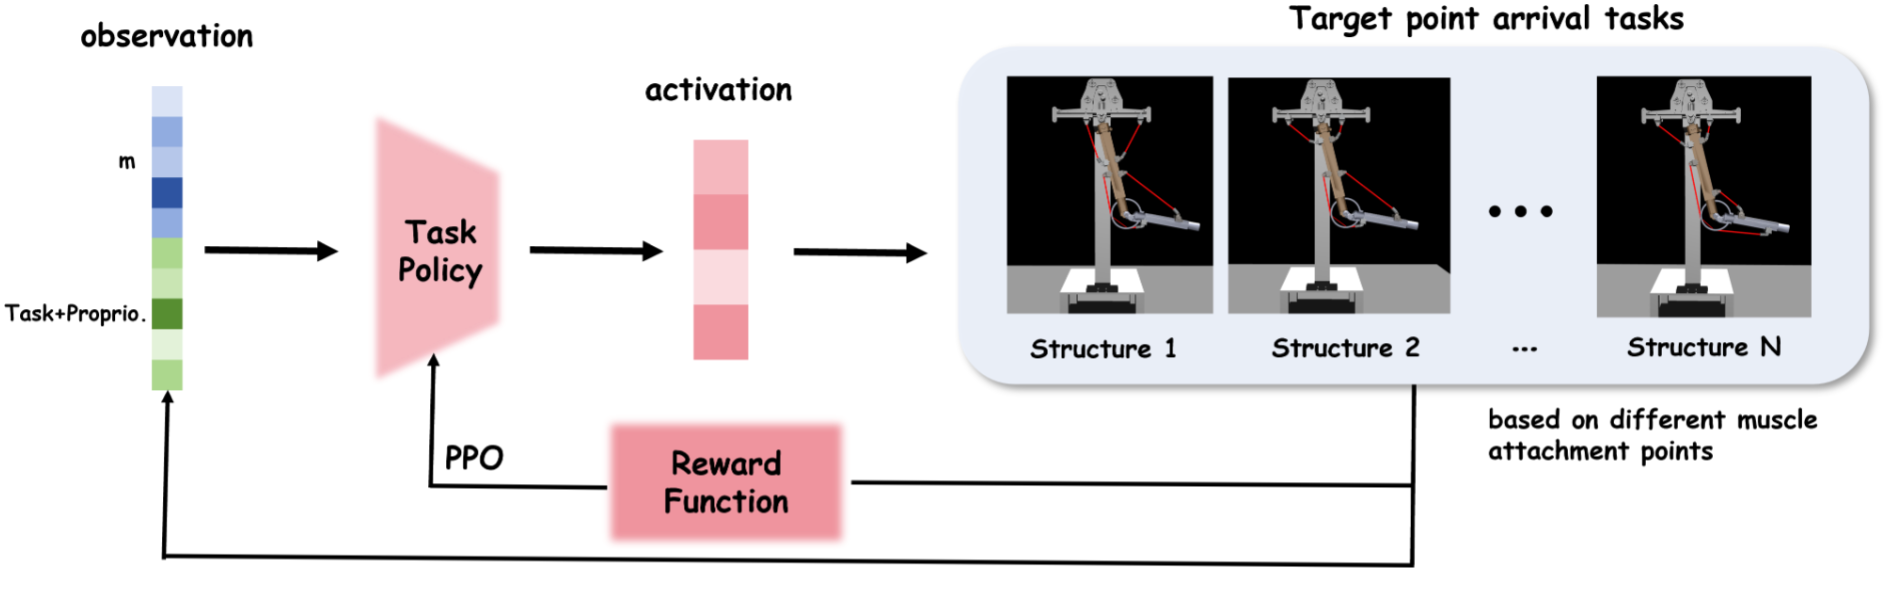
PPO policy learning across musculoskeletal robots with different muscle attachment structures

Learning Morphology-Robust Policy for Variable-Structure Musculoskeletal Robots with Proximal Policy Optimization

Hanwen Cui, Siyuan Liu, Shanlin Zhong

2026 International Conference on Advanced Robotics and Mechatronics · 2026

ICARM2026
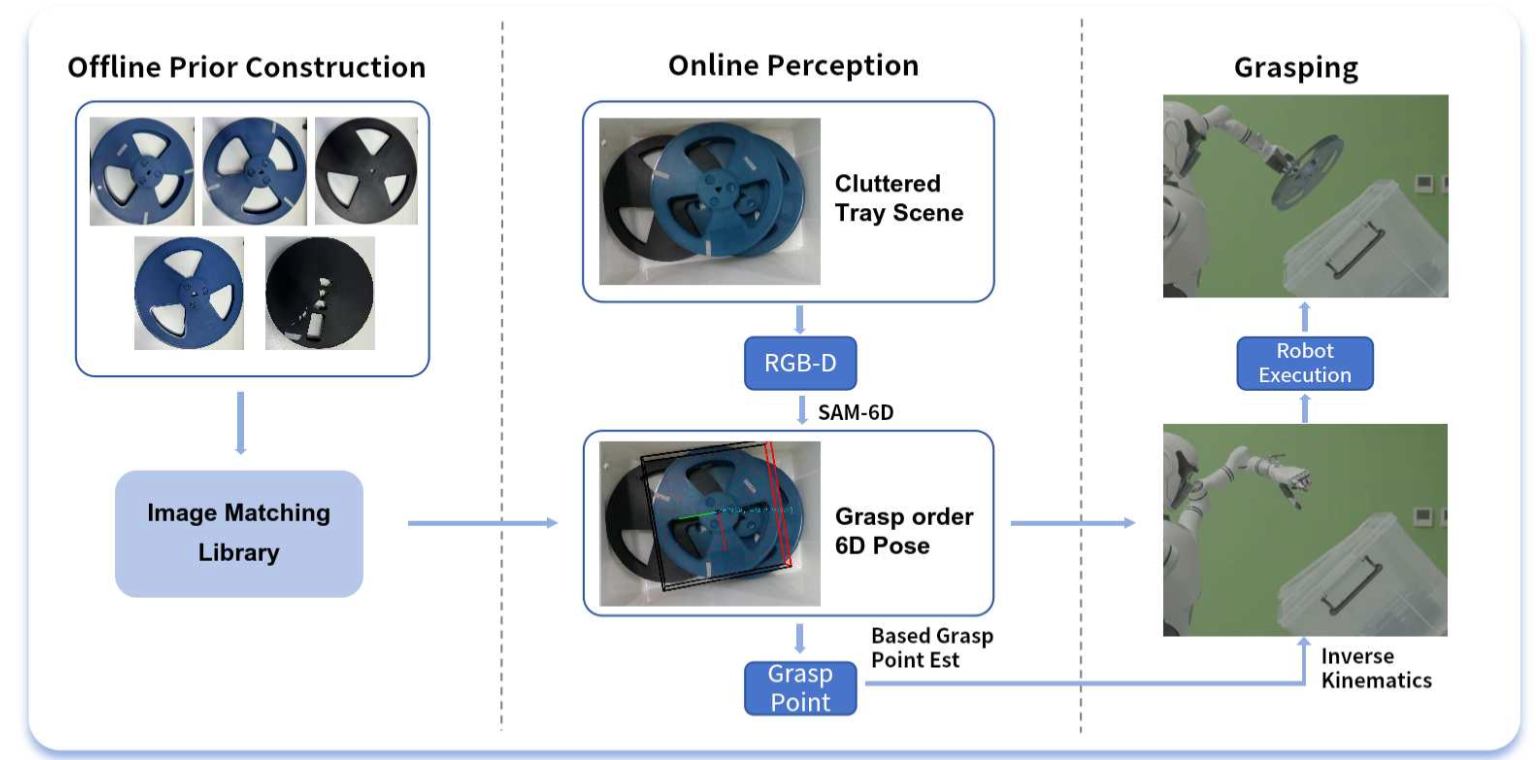
Offline prior construction, online perception, and robot grasping under incomplete observation

Incomplete-observation Grasping with Hidden Geometric Structure

Ci Song, Siyuan Liu, Bo Jiang, Jiahao Chen, Yimin Ji, Si Zhiyuan, Shanlin Zhong

2026 International Conference on Advanced Robotics and Mechatronics · 2026

RIA2026
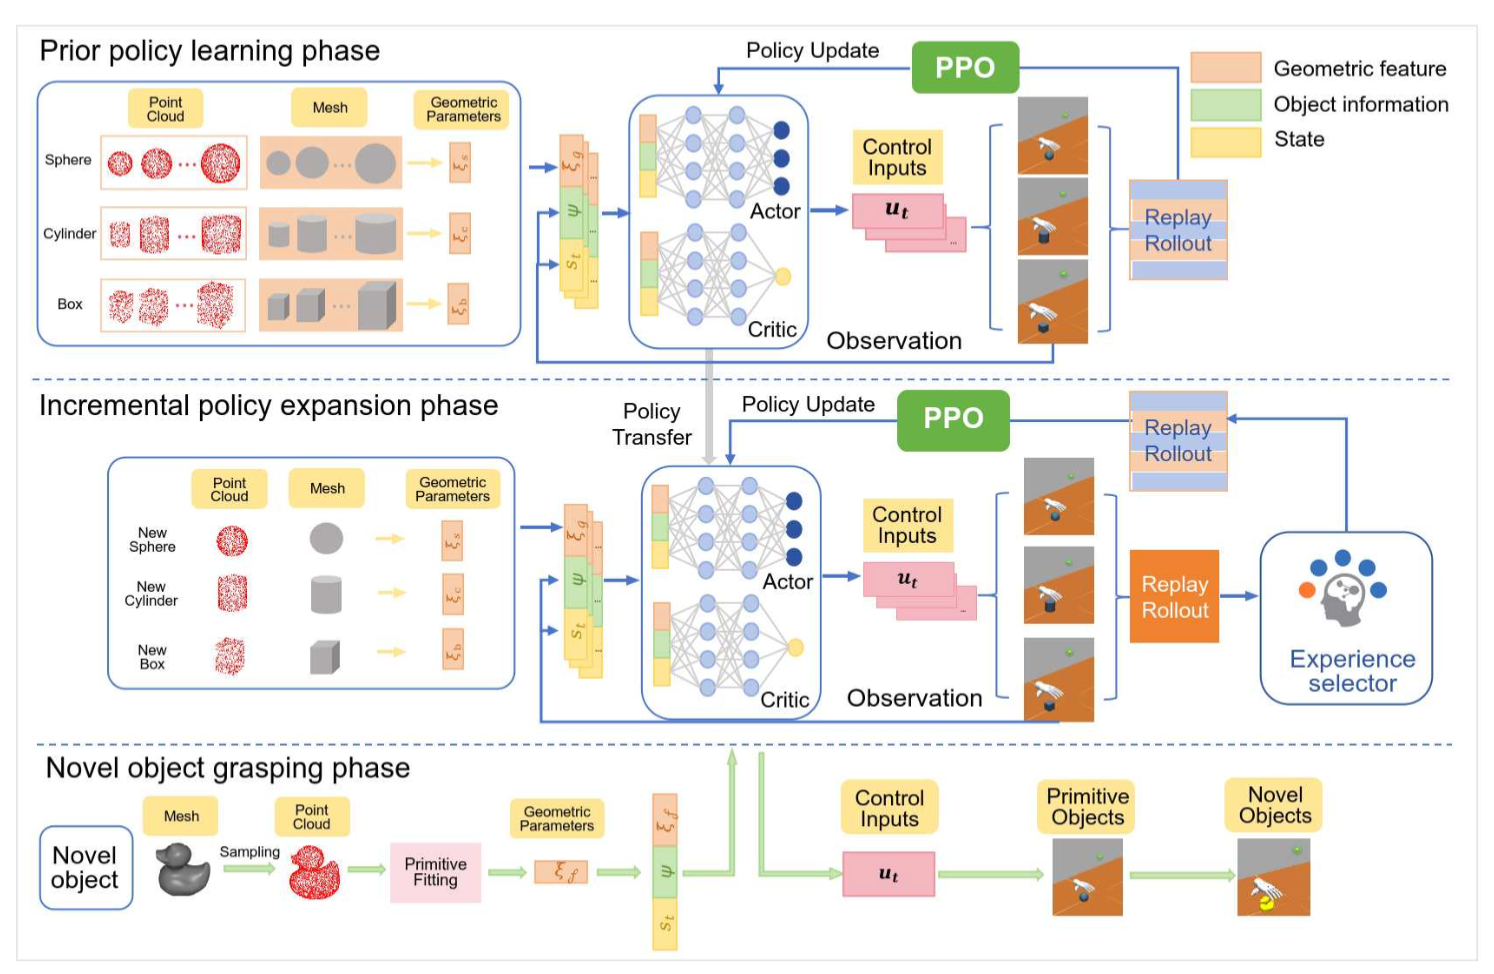
Prior policy learning, incremental policy expansion, and novel object grasping through primitive policy reuse

Generalizable Dexterous Grasping via Primitive Policy Library Reuse and Grasp Part Reasoning

Ci Song, Bo Jiang, Siyuan Liu, Jiahao Chen, Shanlin Zhong

Robotic Intelligence and Automation · 2026

TASE2025
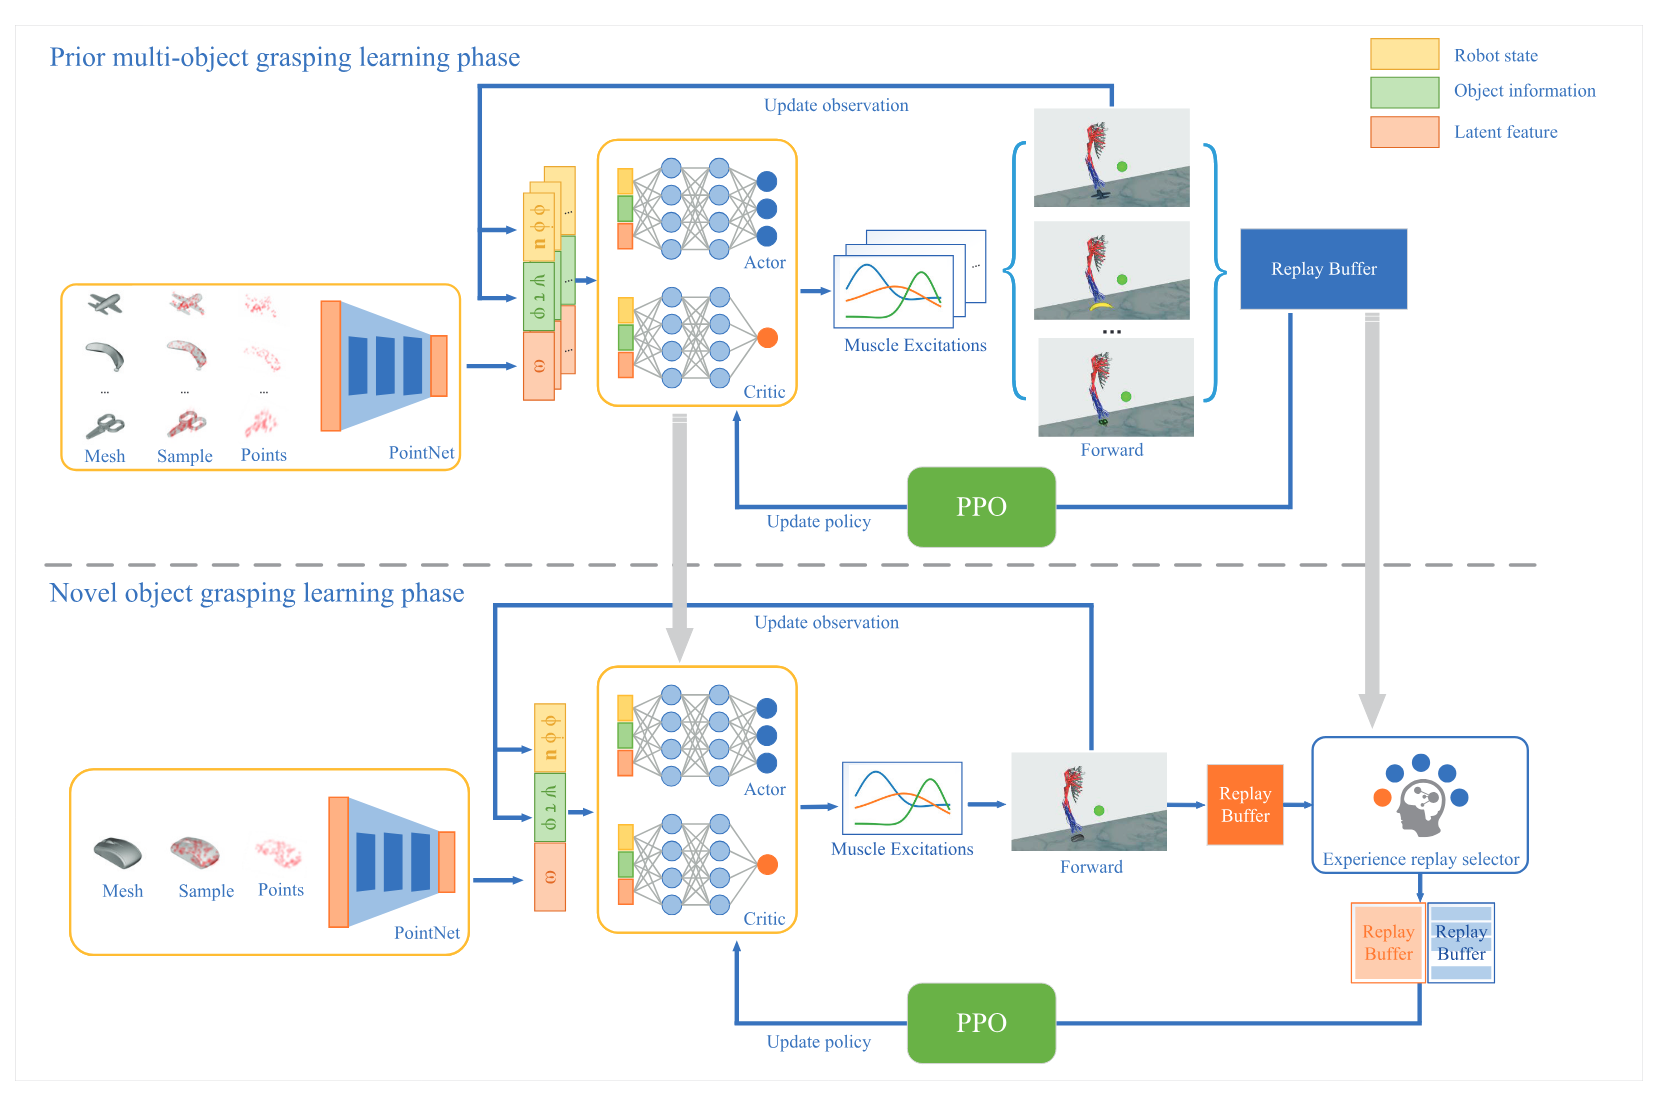
Continual musculoskeletal grasping framework with prior multi-object learning and experience replay for novel objects

A Continual Learning Method for Generalized Grasping Manipulation in a Musculoskeletal Robot

Bo Jiang, Ci Song, Siyuan Liu, Shuai Gan, Jiahao Chen

IEEE Transactions on Automation Science and Engineering · 2025

NeurIPS2026
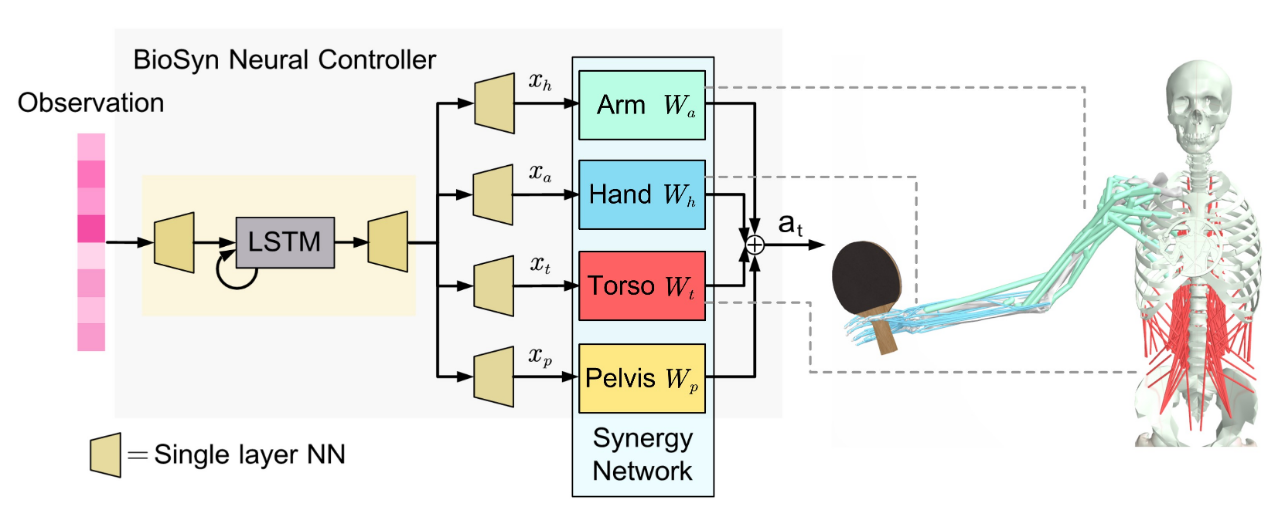
BioSyn neural controller with arm, hand, torso, and pelvis synergy networks for the MyoChallenge 2025 table tennis task

MyoChallenge 2025: A New Benchmark for Human Athletic Intelligence

Cheryl Wang, Chun Kwang Tan, et al., Siyuan Liu, et al. Full author list

Cheryl Wang, Chun Kwang Tan, Balint K. Hodossy, Eric Lyu, Jun Guo, Wentao Zhao, Huaping Liu, Chengkun Li, Merkourios Simos, Bianca Ziliotto, Alexander Mathis, Siyuan Liu, Jiahao Chen, Shanlin Zhong, Bo Jiang, Ci Song, Yaoye Zhu, Chenhui Zuo, Yanan Sui, Mohamed Irfan Refai, Massimo Sartori, Guillaume Durandau, Vikash Kumar, Vittorio Caggiano

NeurIPS 2026 · Datasets and Benchmarks Track · Accepted

Education

Institute of Automation, Chinese Academy of Sciences (CASIA)

Direct-entry Ph.D. program

2023 – 2028

Harbin Institute of Technology

B.Eng. in Measurement and Control Technology and Instrumentation

2019 – 2023

Honors & Awards

NeurIPS MyoChallenge 2025

Runner-up · Table Tennis Track · Team BioSyn

Team BioSyn certificate: second place in the NeurIPS MyoChallenge 2025 Table Tennis Track, awarded to Siyuan Liu, Jiahao Chen, Shanlin Zhong, Bo Jiang and Ci Song.View certificate

Academic Service

Journal reviewer

  • IEEE Transactions on Automation Science and Engineering (TASE)
  • IEEE Transactions on Cognitive and Developmental Systems (TCDS)
  • IEEE Transactions on Fuzzy Systems (TFS)

Conference reviewer

  • IEEE International Conference on Robotics and Automation (ICRA)
  • International Joint Conference on Neural Networks (IJCNN)
  • IEEE Engineering in Medicine and Biology Society Annual International Conference (EMBC)